Abstract
Multi-robot path planning in human-shared environments requires a delicate balance between robust inter-robot coordination and socially aware behavior. While diffusion models excel at generating predictable, human-like paths, existing generative planners are often restricted to paths of fixed duration and high computational latency, limiting their adaptability to varying goal distances and hindering real-time deployment. We present Multi-Robot Rolling Diffusion (MRRD), a novel framework that enables real-time, long-horizon navigation for large robot teams through dense crowds. MRRD combines a rolling-horizon scheme to accommodate the limited prediction horizon of human motion, parallelized diffusion inference for scalable generation of human-like paths, and a conflict-based-search mechanism for resolving inter-robot collisions. It further incorporates urgency-based temporal conditioning to generate paths with varying speeds and employs differentiated guidance terms to maximize both social awareness around humans and efficient coordination between robots. Experimental results in crowded environments demonstrate that MRRD successfully scales to 15 robots in real-time, significantly outperforming existing baselines in both safety and mission success rates.
Three-Level Diffusion Planning
Rolling Horizon Planning
Rolling Horizon
Generate Short Path Segments
Human Prediction
Human Location Lookahead over Planning Horizon
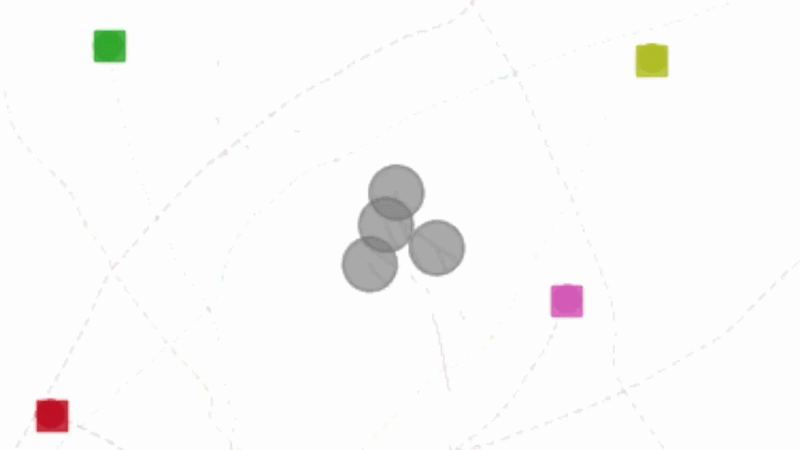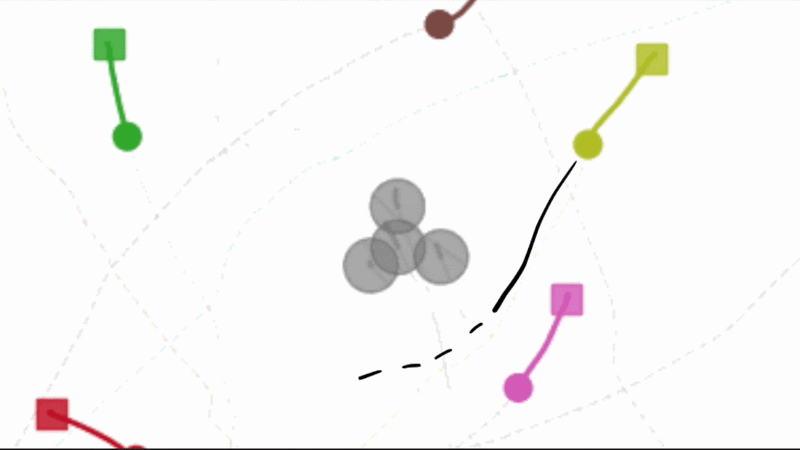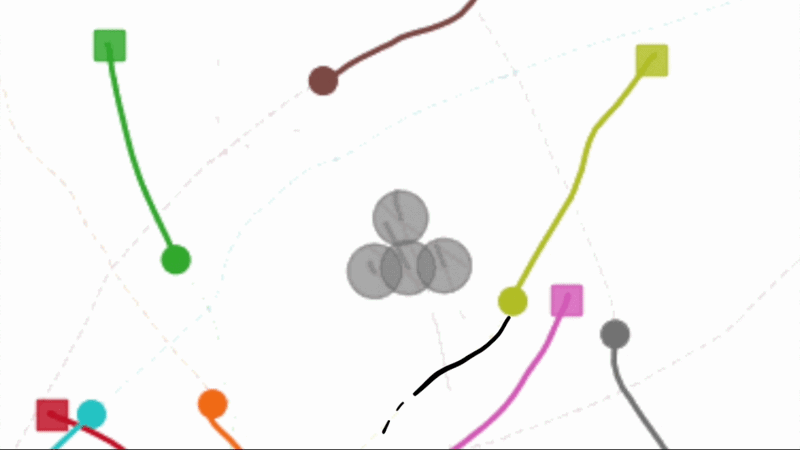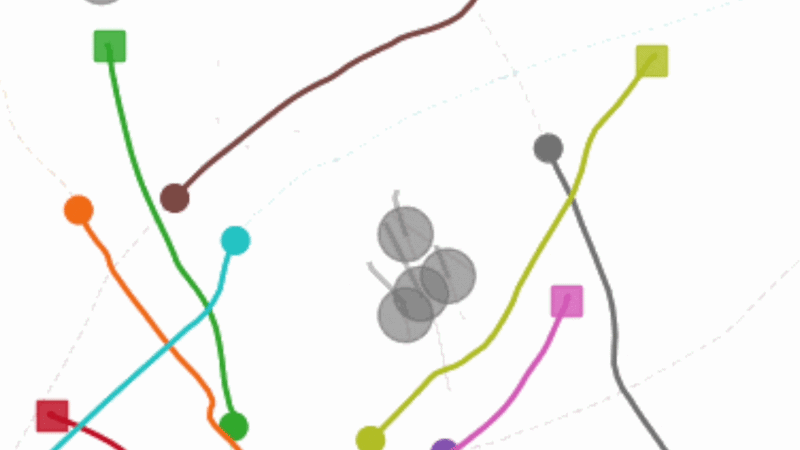
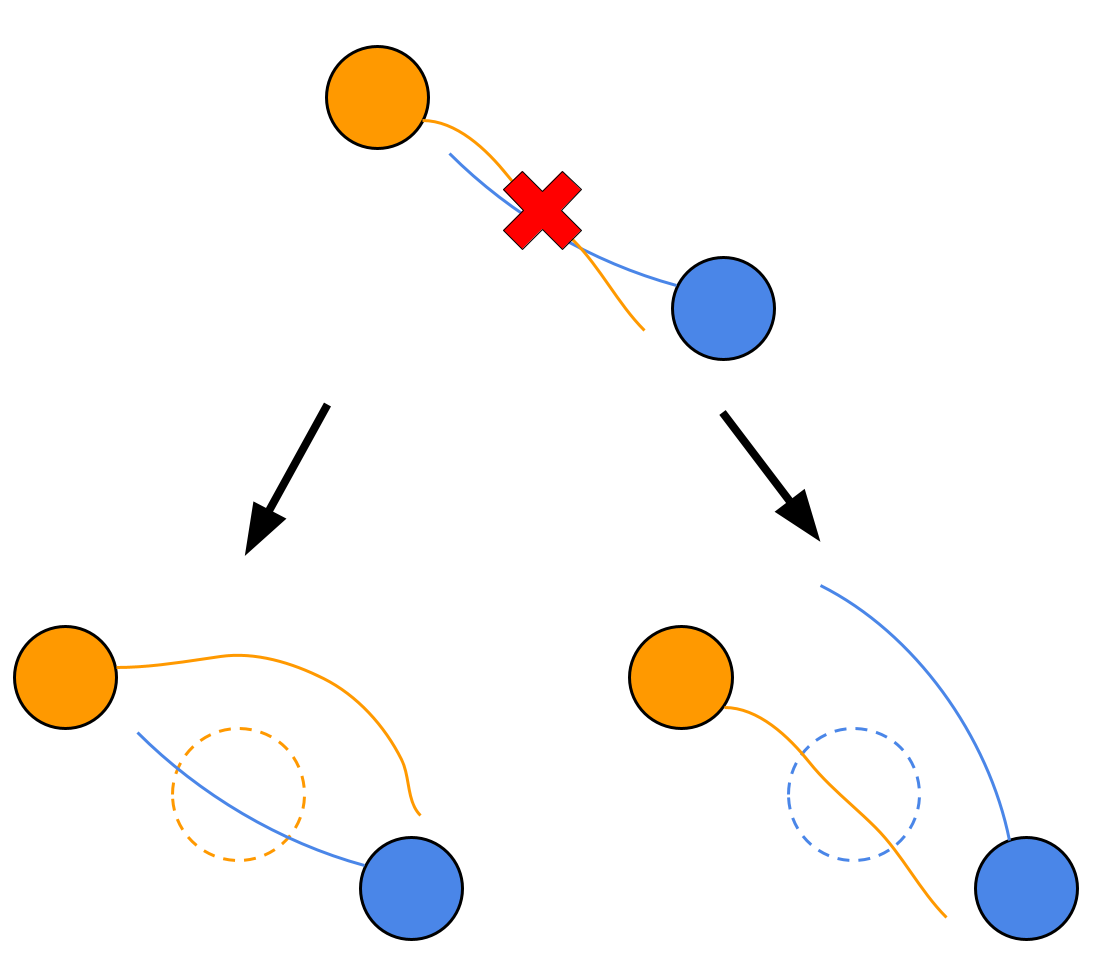
Multi-Robot Coordination
Conflict-Based Search
Resolves inter-robot collision conflicts across the team
Parallelized Inference
Scalable trajectory generation for dense robot teams in real time
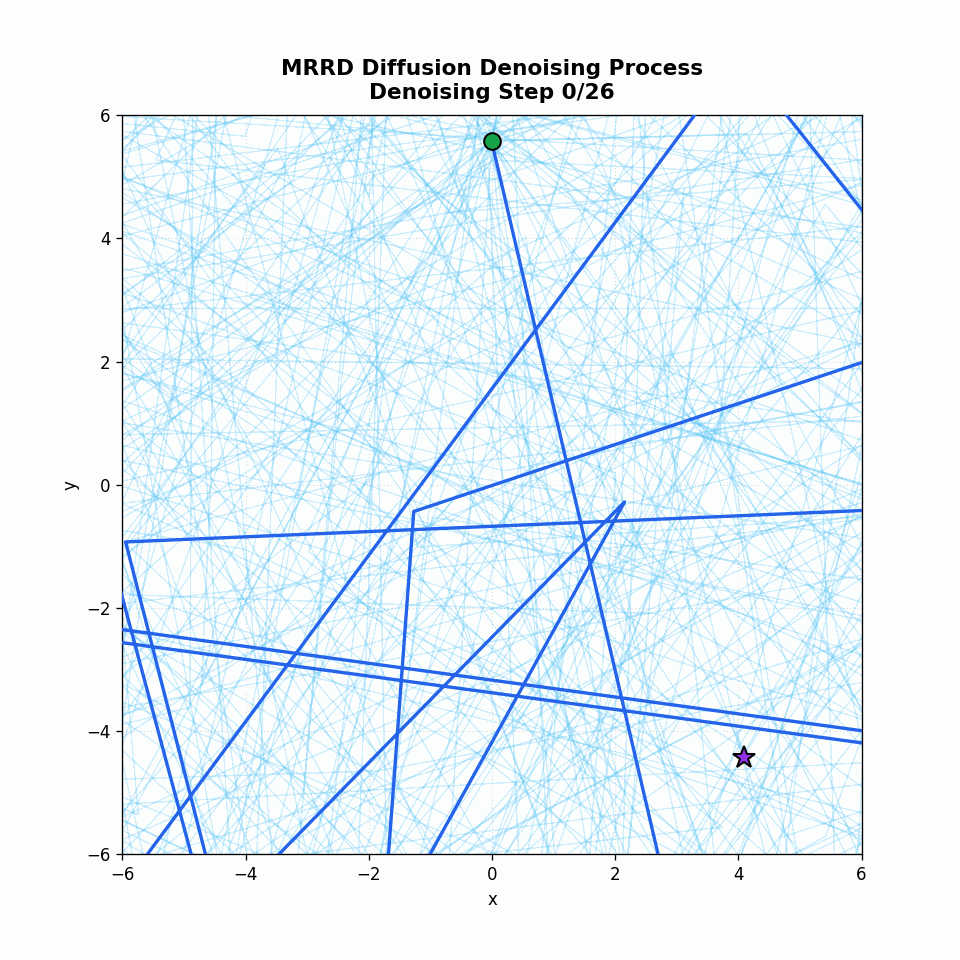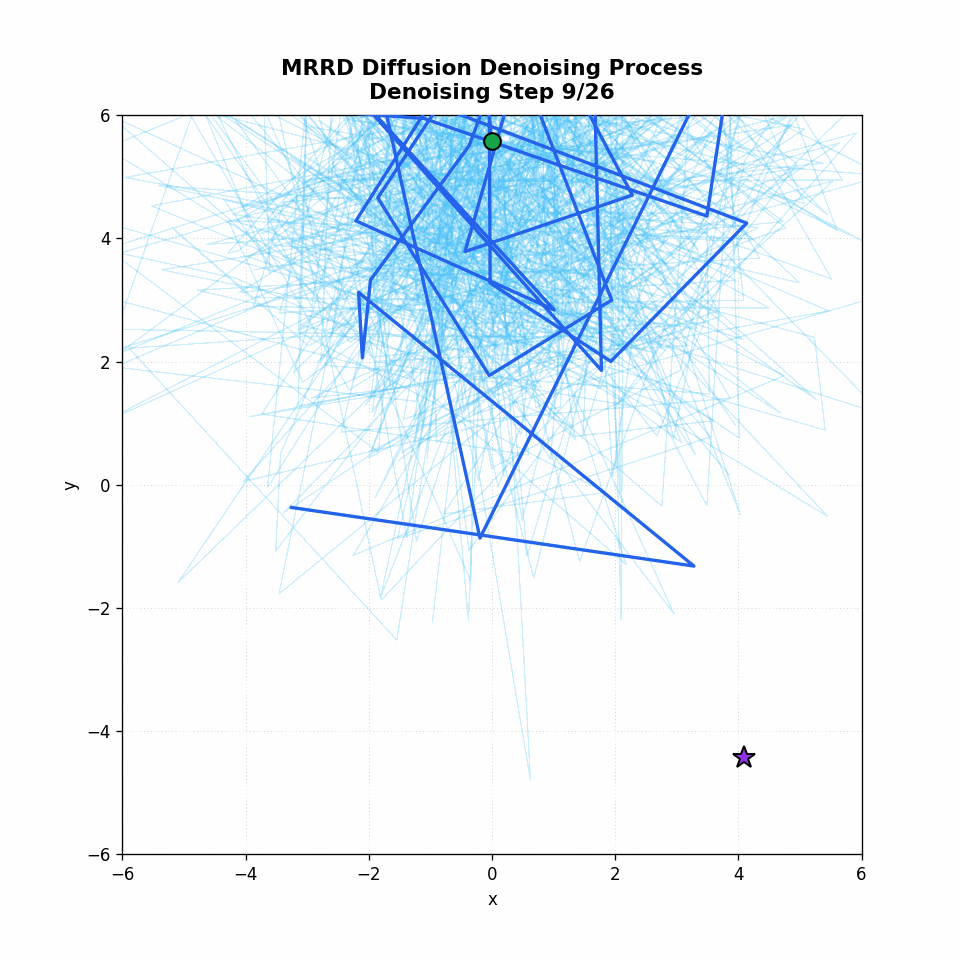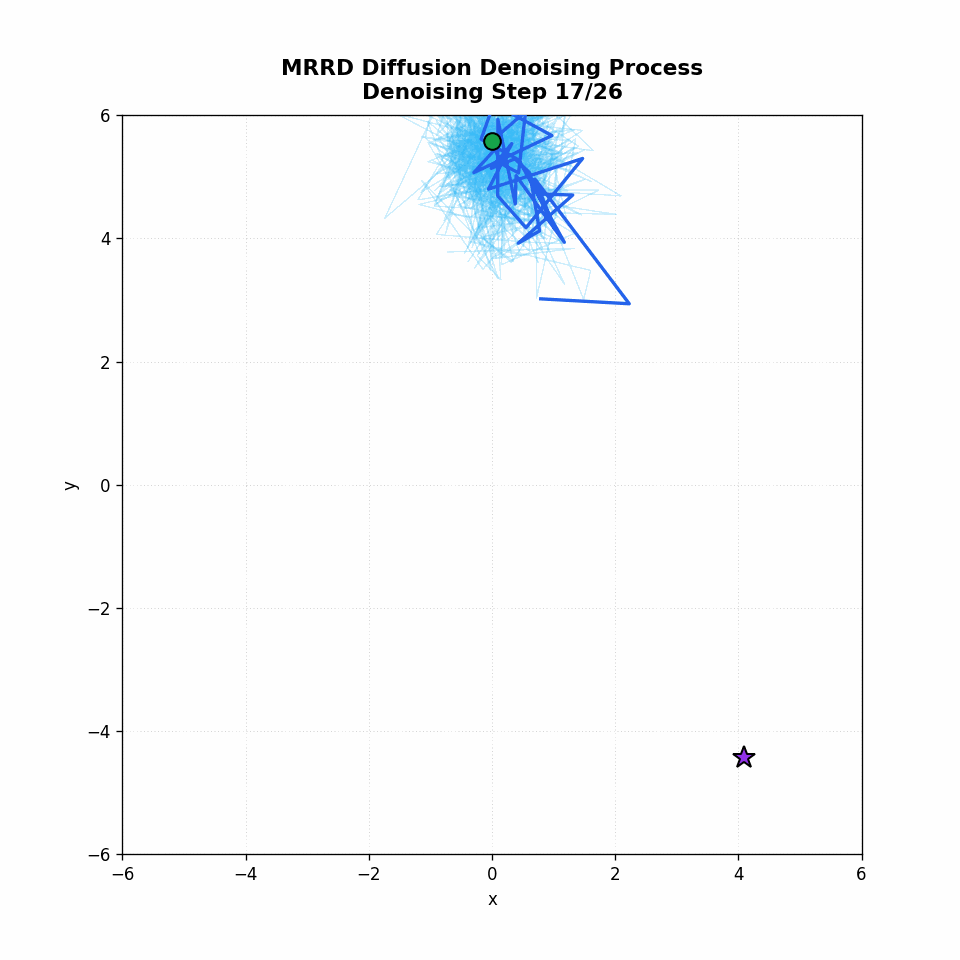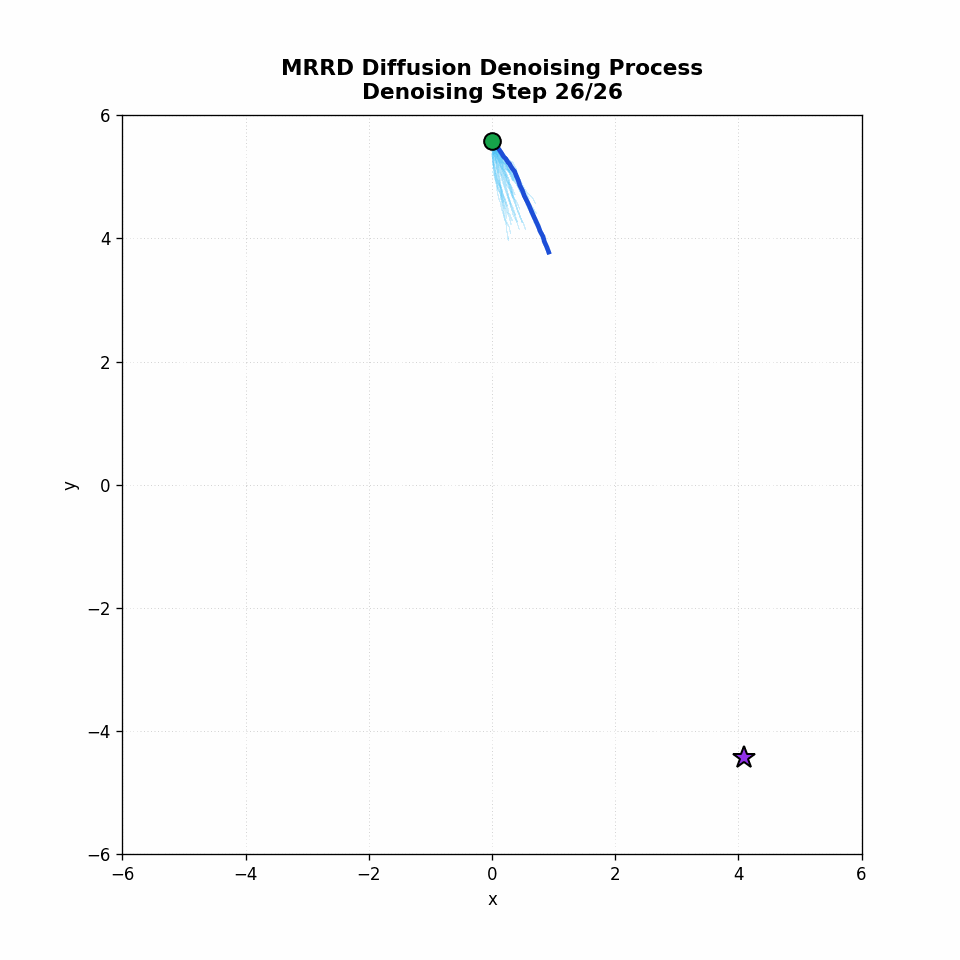
Single-Robot Diffusion Planning
Urgency-Based Conditioning
Temporal conditioning to generate a batch of paths with varying speeds
Gradient Guidance
Guides generation to resolve task objectives
Examples
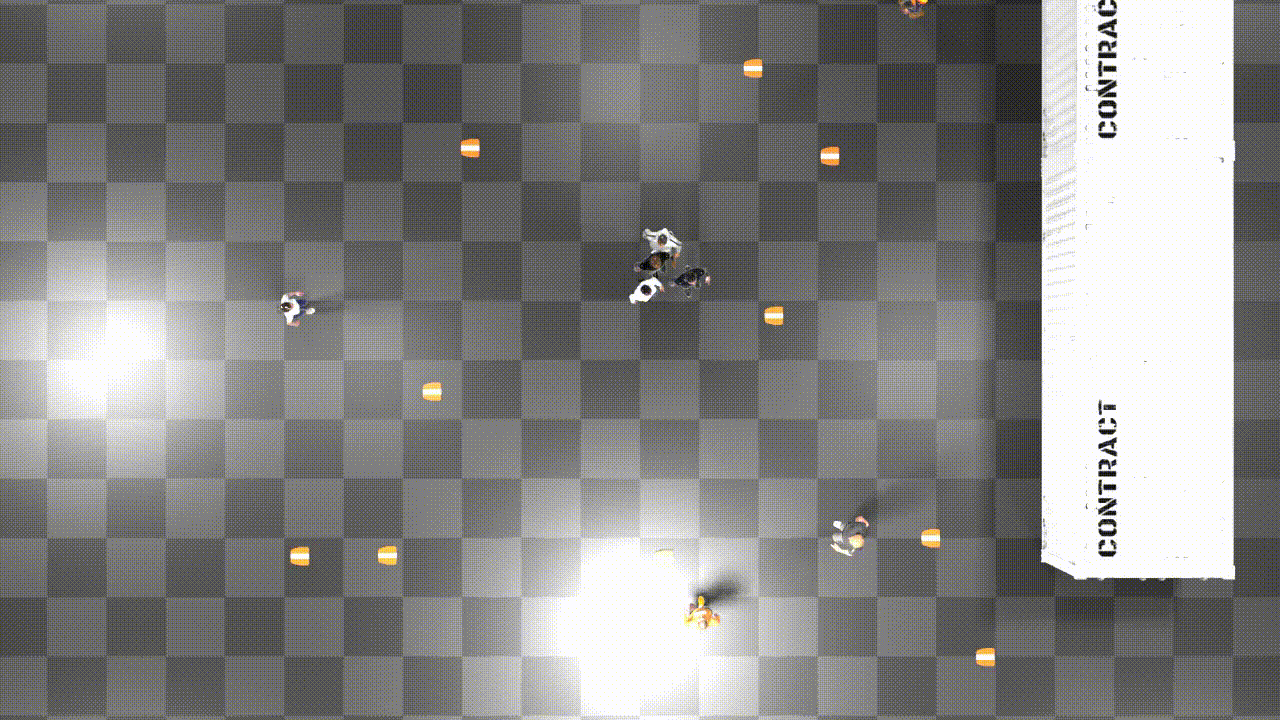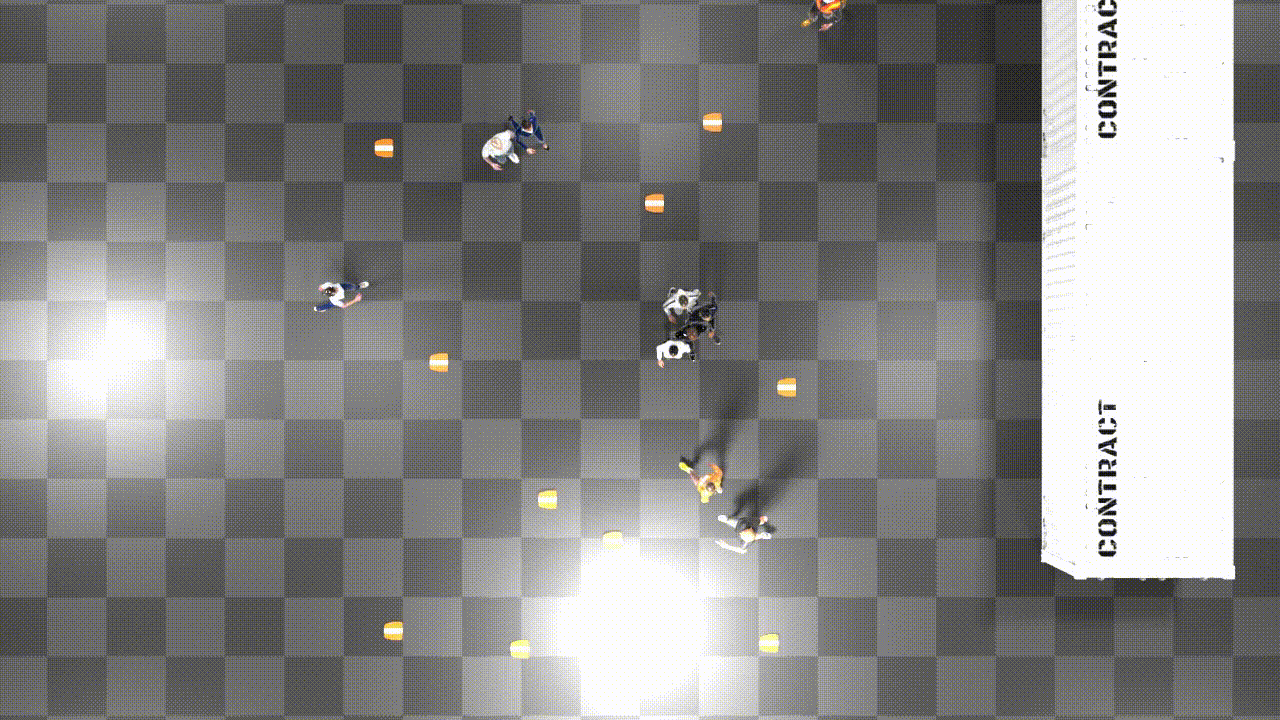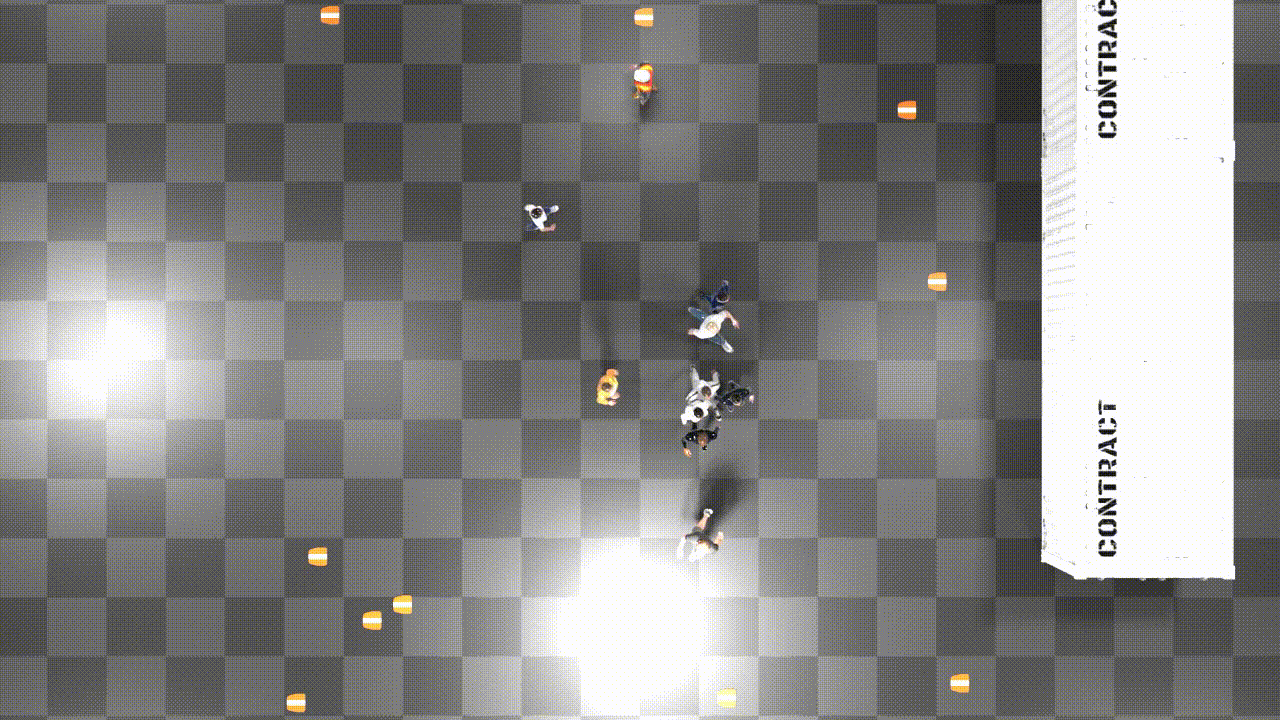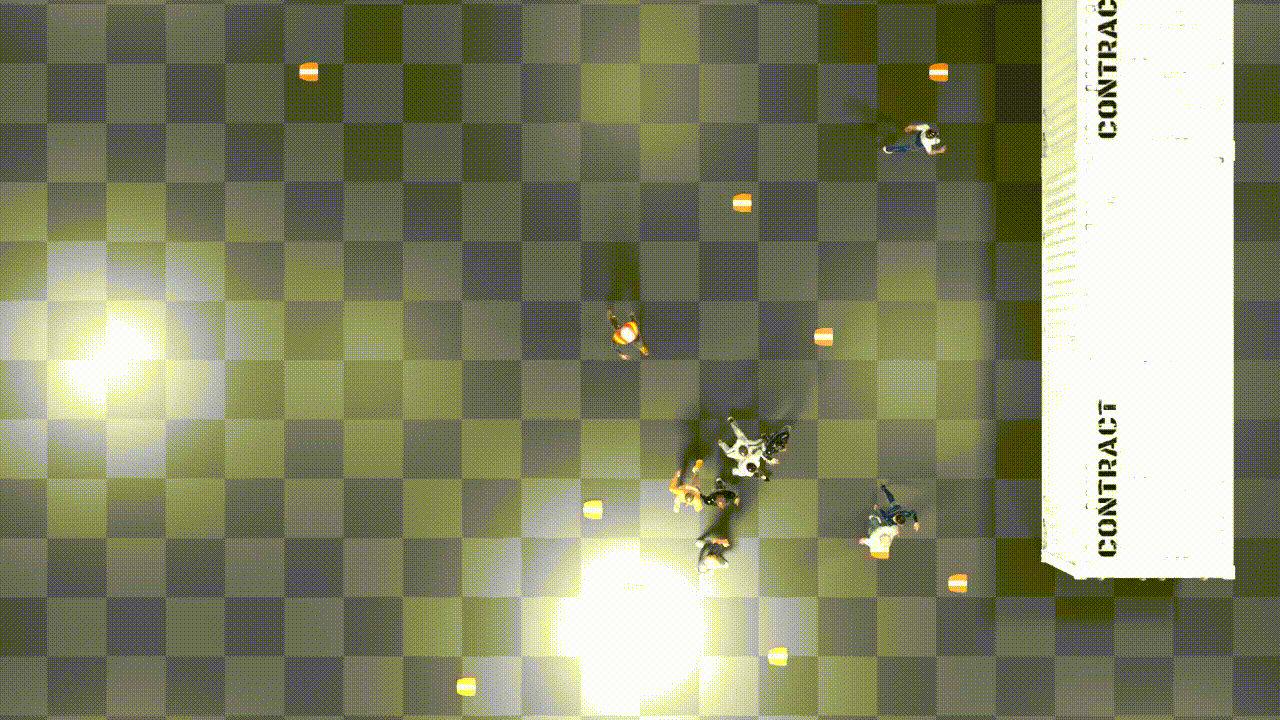
Top down view of MRRD in Blender.
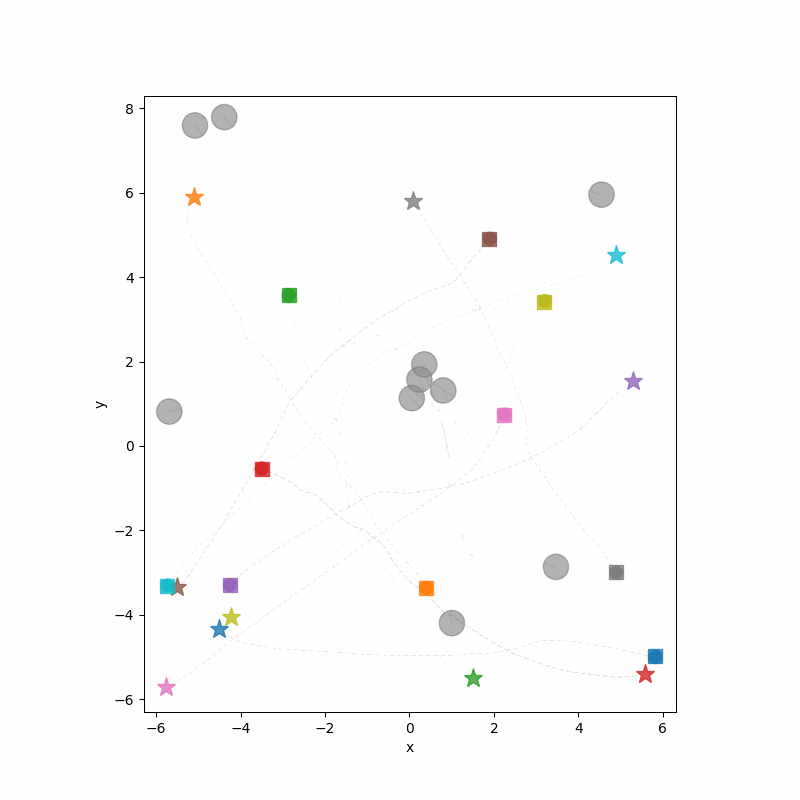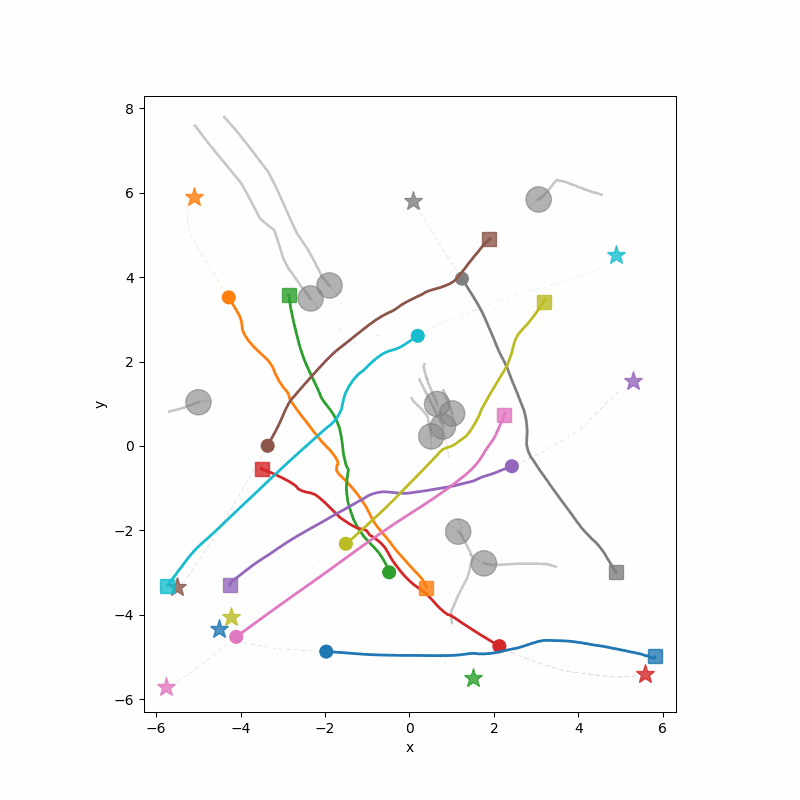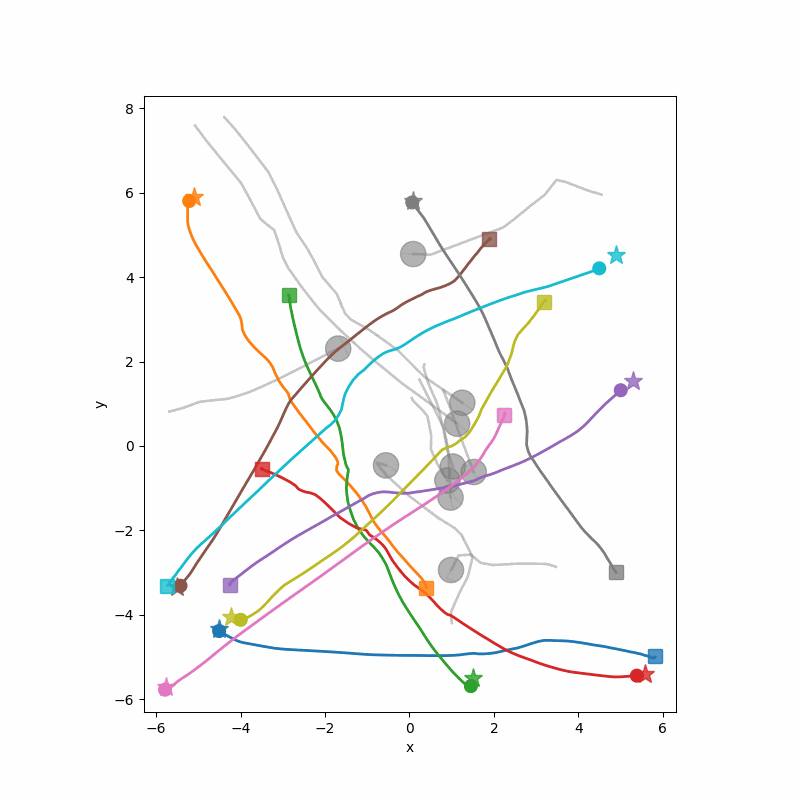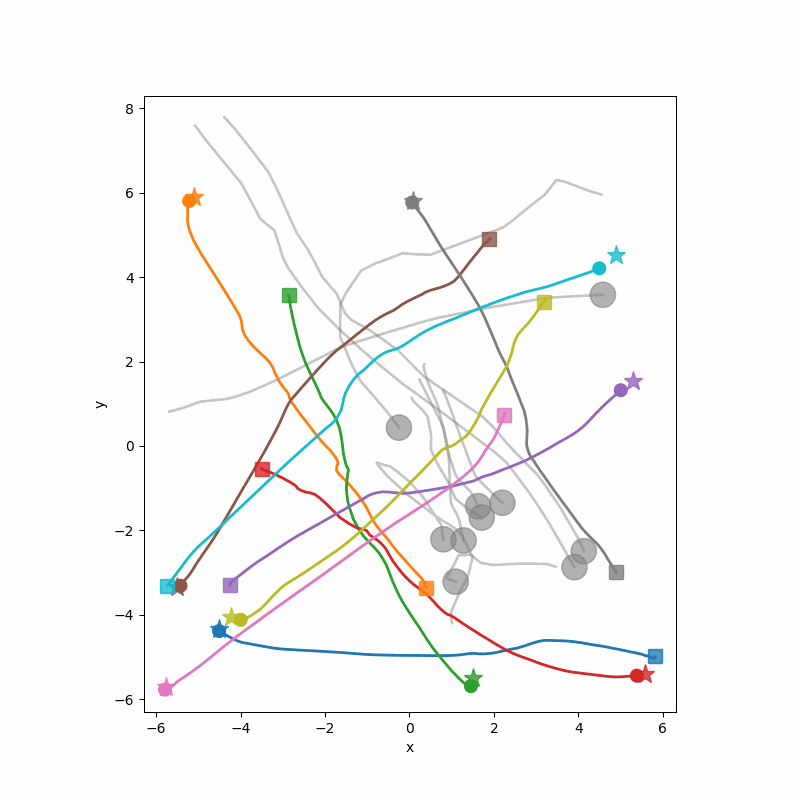
MRRD navigation in empty environment with 10 robots.
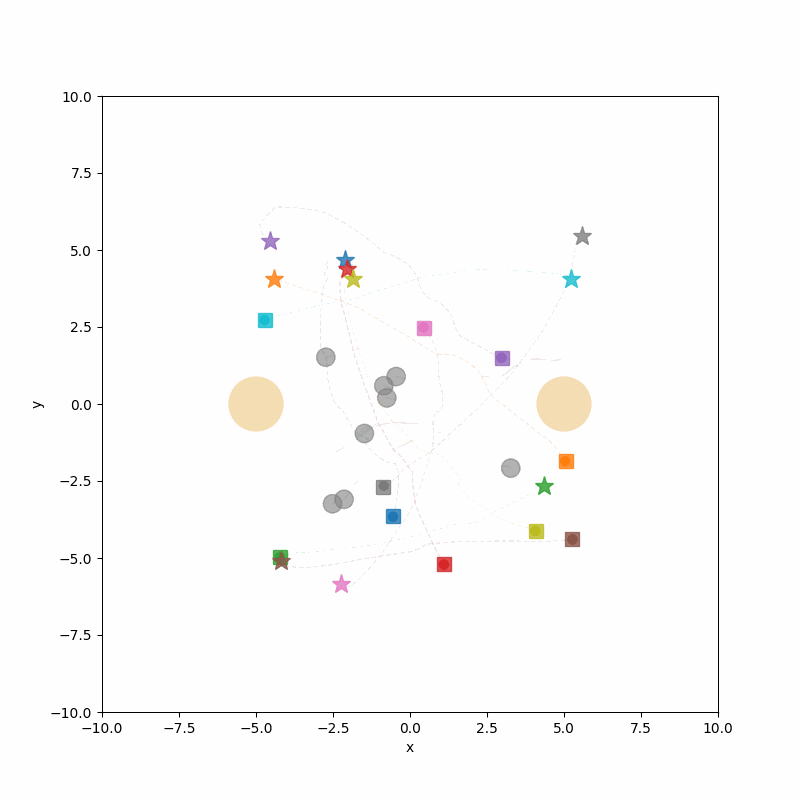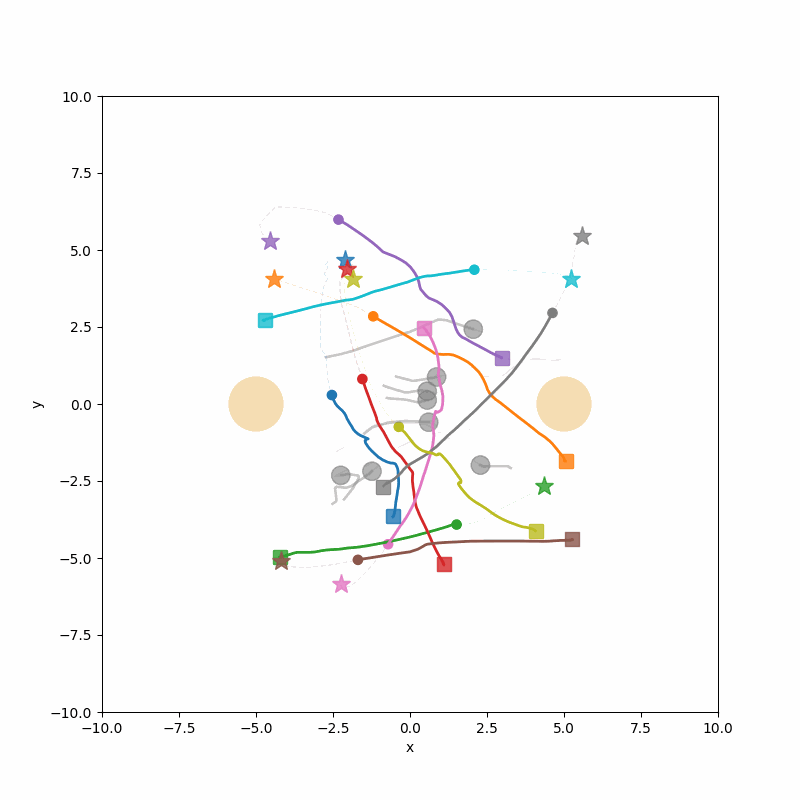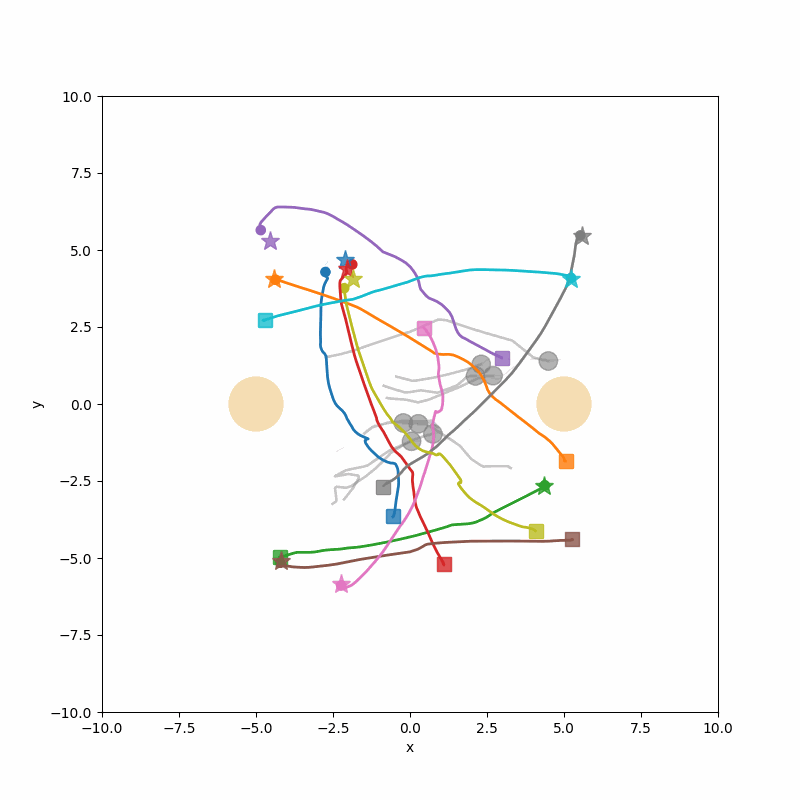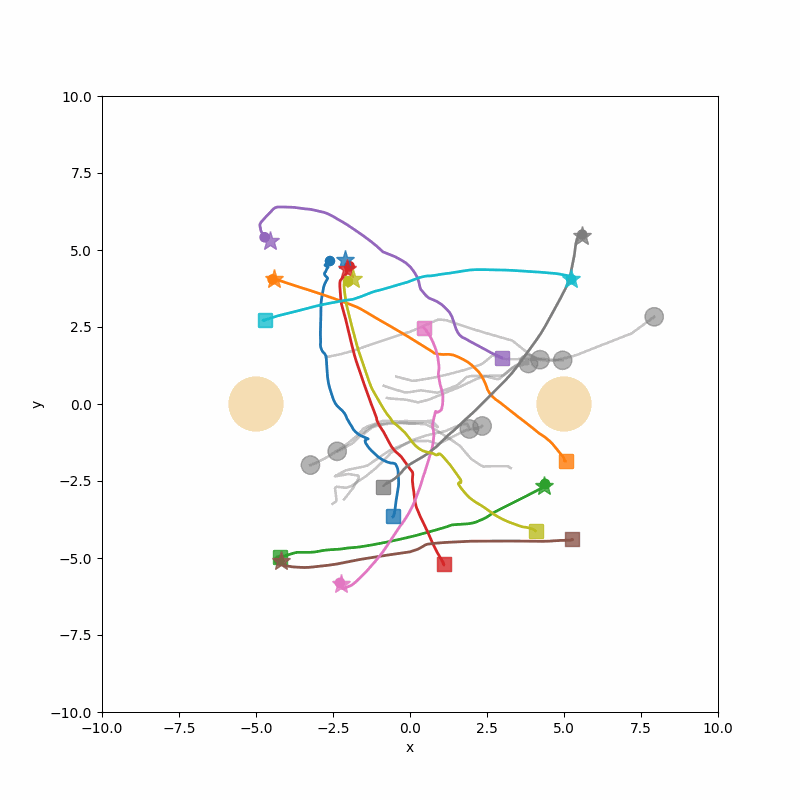
MRRD navigation in simple environment with 10 robots.
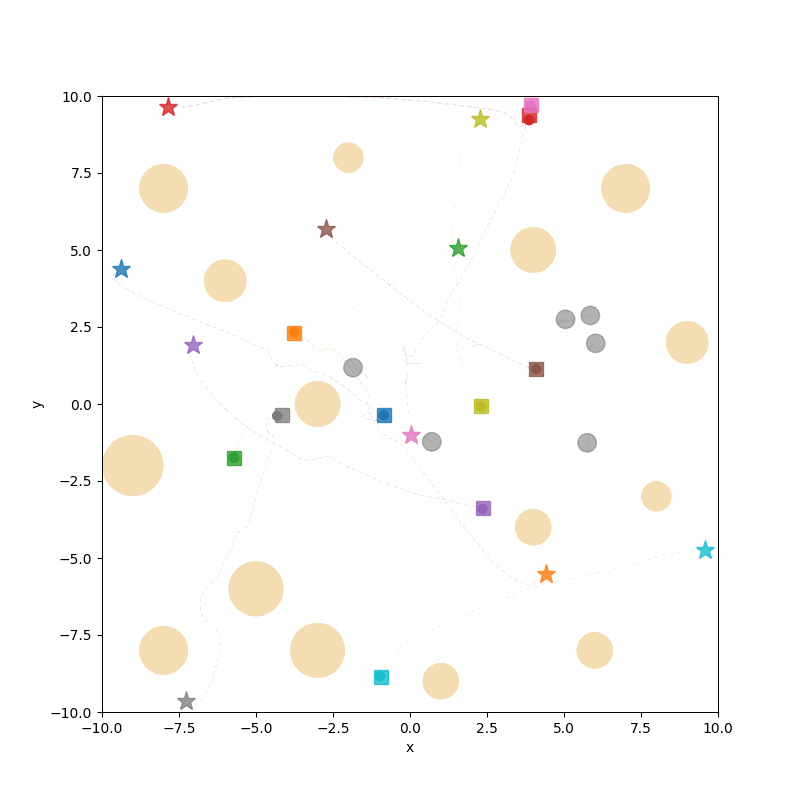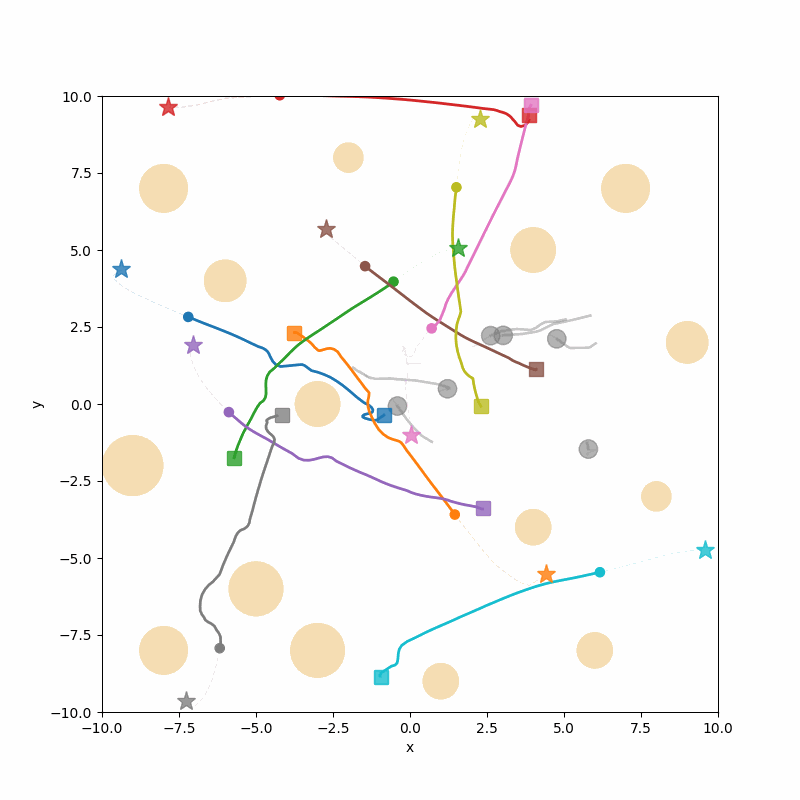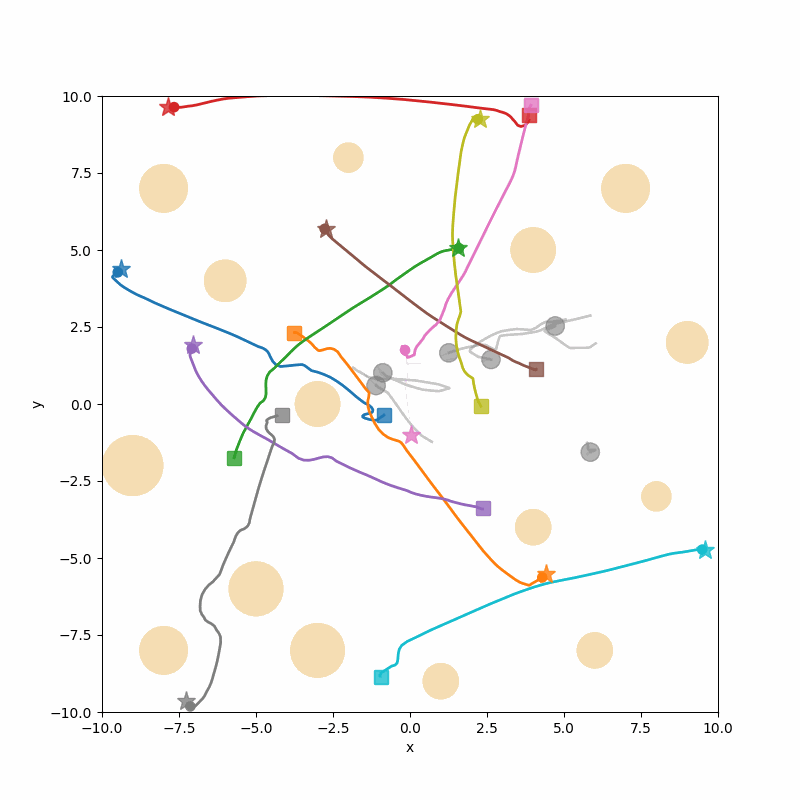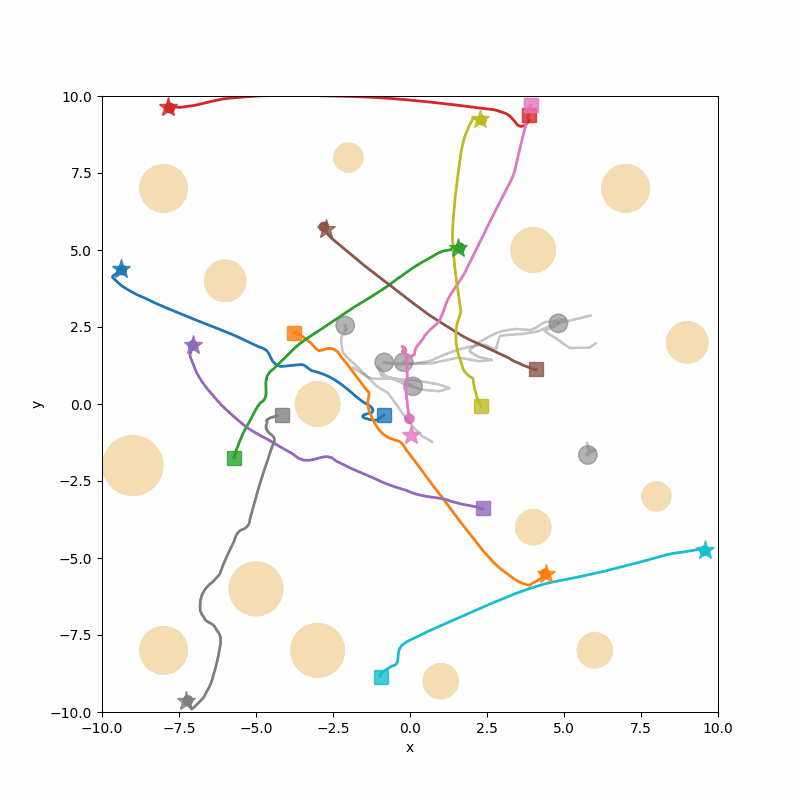
MRRD navigation in spheres environment with 10 robots.
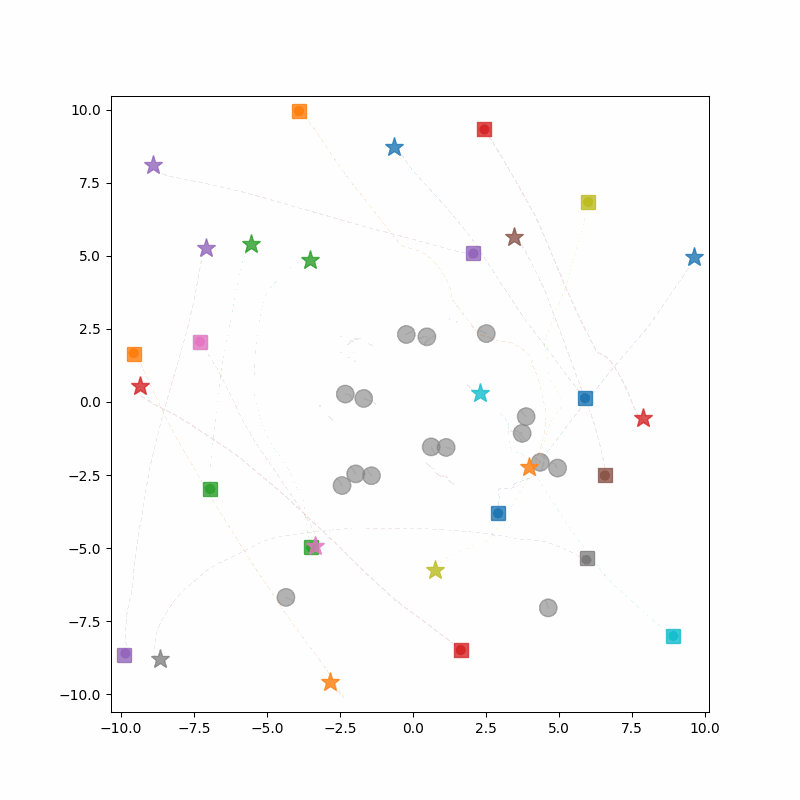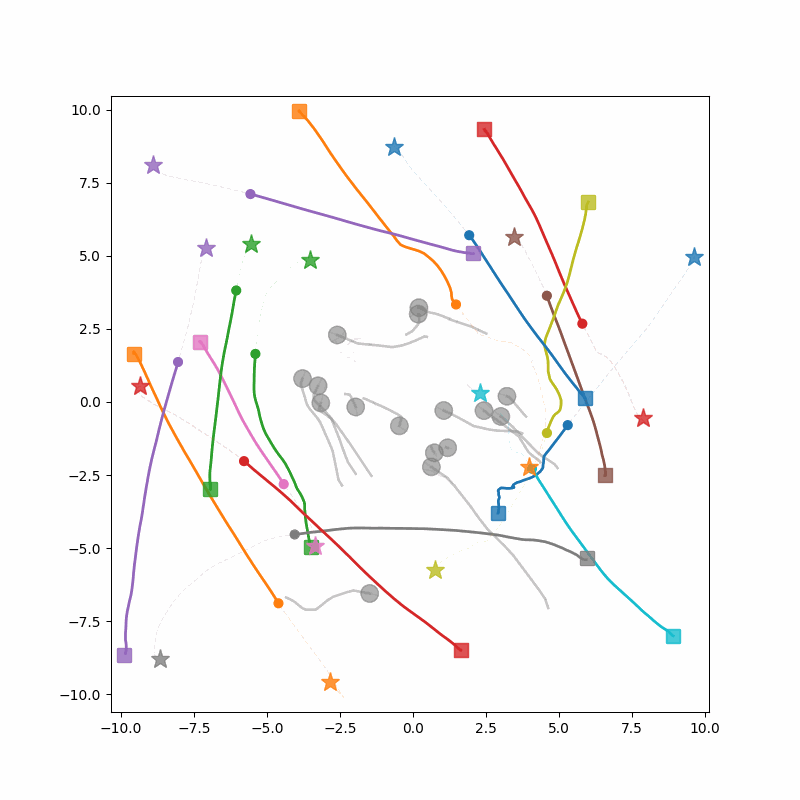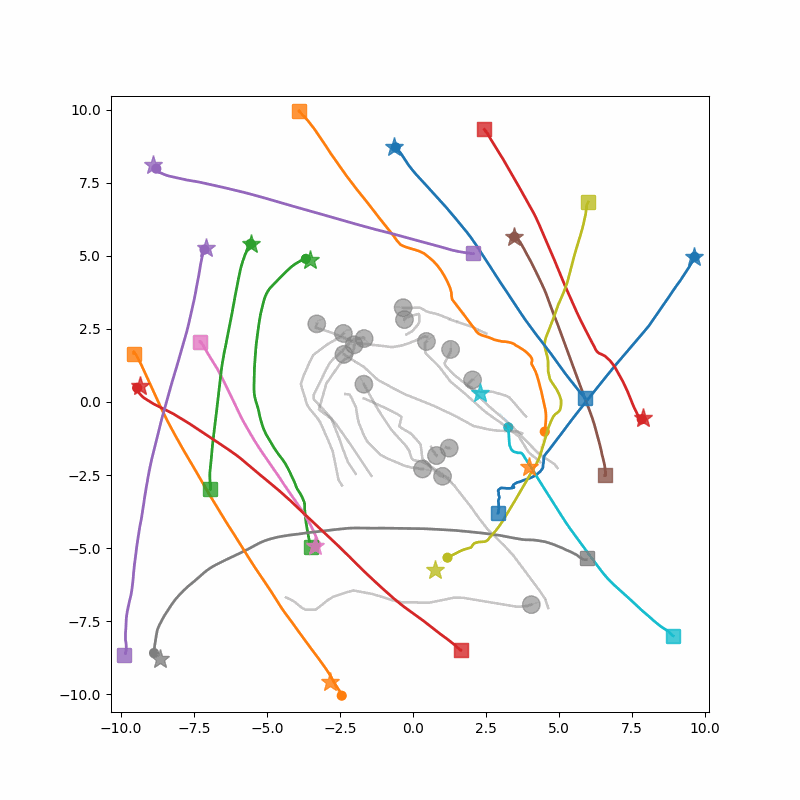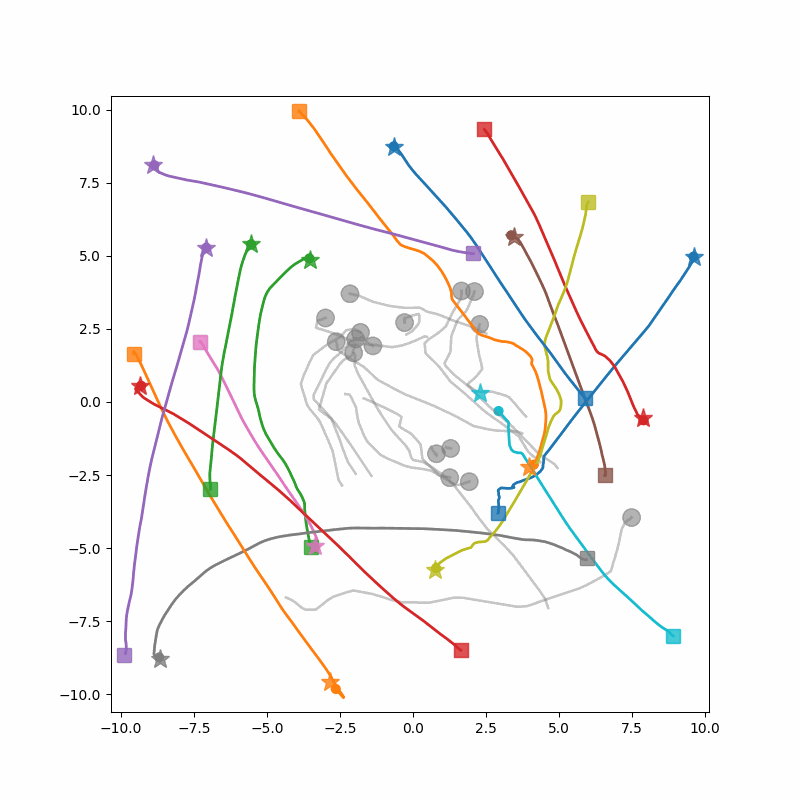
MRRD navigation in empty environment with 15 robots.
BibTeX
@article{MRRD2026,
  title={Diffusion for Long-Horizon Multi-Robot Path Planning in Human-Shared Environments},
  author={Sanjay, Vaibhav and Shaoul, Yorai and Li, Jiaoyang},
  booktitle = {IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)},
  year={2026}
}